AEROTECH Automation1 iXC4e Enhanced, PWM Servo Drive with Motion Controller
Automation1 iXC4e Enhanced, PWM Servo Drive with Motion Controller
The iXC4e is the powerful center of your motion control architecture. It has a full motion controller, connects to other Automation1 drives over HyperWire and connects to other automation devices over EtherCAT, EtherNet/IP™, Modbus TCP/IP or a TCP Socket interface.
Design Features
Unlock the full motion control power of our Automation1 iSMC intelligent software-based motion controller
Features complete configuration & performance capability of XC4e servo motor drive
Connect to the controller using EtherCAT, EtherNet/IP, Modbus or a Socket interface
Enjoy up to 12 axes of control by connecting more Automation1 drives over the HyperWire fiber-optic bus
Expand your I/O by adding expansion board to the iXC4e or to other connected drives
Motion. Control. Together.
The Automation1-iXC4e, a hardware platform for running the Automation1-iSMC intelligent software-based motion controller, features a servo motor drive. That means it has the ability to run your entire machine’s control, act as a servo drive for a single axis and control up to 11 added axes of motion over our fiber-optic HyperWire motion bus. The supported EtherCAT, EtherNet/IP, Modbus TCP and Socket interface enable true full machine and motion system control. Combining this technology on a single hardware device lowers your machine costs, reduces machine size and increases reliability.
The iSMC, which runs on the iXC4e, is programmable in AeroScript from the Automation1 Studio application and several available APIs.
Automation1 iXC4e Device Specifications
Specification | Description |
Motion Controller(1) | Aerotech’s Automation1 iSMC Intelligent Software-Based Motion Controller (version 2.00 and above) |
Motor Style | Brush, brushless, voice coil, stepper(2) |
Motor Supply | Single-phase 0-240 VAC; 50/60 Hz |
Control Supply | 100-240 VAC; 50/60 Hz |
Bus Voltage(3) | 0-340 VDC |
Peak Output Current (1 sec)(4) | 10 Apk | 20 Apk | 30 Apk |
Continuous Output Current(4)(5) | 5 Apk | 10 Apk | 10 Apk |
Position Synchronized Output (PSO) | Standard: One-axis PSO (includes one-axis part-speed PSO) |
25-Pin Motor Feedback Connector | High-speed differential inputs (encoder sin, cos and marker) |
26-Pin Auxiliary Feedback Connector | High-speed differential inputs (encoder sin, cos and marker)* |
Multiplier Options | MX0 Option: |
I/O Expansion Board (-EB1) | 1x additional PSO connection point |
Drive Array Memory | 16,777,216 32-bit elements (67 MB) |
High-Speed Data Capture | Yes (50 ns latency) |
Safe Torque Off (STO) | Yes, SIL3/PLe/Cat 4 |
HyperWire Connections | 1x HyperWire small form-factor pluggable (SFP) ports |
Automatic Brake Control | Standard; 24 V at 1 A |
Absolute Encoder | Renishaw resolute BiSS; EnDat 2.1; and EnDat 2.2 |
Current Loop Update Rate | 20 kHz |
Servo Loop Update Rate | 20 kHz |
Power Amplifier Bandwidth | Selectable through software (85-95% efficiency) |
Minimum Load Inductance | 0.1 mH |
Operating Temperature | 0 to 40°C |
Storage Temperature | -30 to 85°C |
Weight | 2.36 kg (5.20 lb) |
Compliance | CE approved, NRTL safety certification, EU 2015/863 RoHS 3 directive |
| User name | Member Level | Quantity | Specification | Purchase Date |
|---|


-
 CTI 2500 Series® Slice Ethernet Remote I/O System
-
 CTI 2500 Series® Compact Programmable Automation Control System
-
 CTI 2500 Series® Classic Programmable Automation Control System
-
 CTI 2500 Series® Bases
-
 SHINKAWA VM-25 Condition Monitoring System UPDATED
-
 SHINKAWA VM-5 SERIES OPTIONS
-
 ABB SACO 64D4 Annunciator unit
-
 ABB SPAU 140 C Synchro-check relay
-
 EATON Instructions for the FP-5000
-
 HONEYWELL TDC 3000X Advanced Process Manager
-
 HONEYWELL ENHANCED MICRO TDC 3000
-
 VIBRO-METER VM600Mk2/ VM600 RPS6U rack power supplies
-
 VIBRO-METER VM600Mk2/ VM600 ABE056 slimline rack
-
 VIBRO-METER VM600Mk2 RLC16Mk2 relay modules
-
 VIBRO-METER VM600Mk2 MPC4Mk2 + IOC4Mk2 machinery protection and condition monitoring modules
-
 VIBRO-METER VM600Mk2 CPUMMk2 + IOCNMk2 rack controller and communications interface module
-
 VIBRO-METER VM600Mk2 CPUMMk2 + IOCNMk2 rack controller and communications interface module
-
 ADLINK PCI/PCIe-7300A, cPCI-7300 32-CH 80 MB/s High-Speed Digital I/O Cards
-
 ADLINK cPCI-7248/7249R 48-CH DIO & Timer/Counter Cards
-
 ADLINK PCI-7230/7233/7234. LPCI/LPCIe/cPCI-7230 32-CH Isolated DIO Cards
-
 ADLINK cPCI-6965 Series Value 6U CompactPCI® Intel® Core™2 Duo
-
 ADLINK cPCI-6910 Series 6U CompactPCI® Dual-Core Intel® Xeon® Processor LV / ULV Universal Blade
-
 ADLINK CPCI-6670 6U CompactPCI Low Power Pentium® III SBC
-
 ADLINK cPCI-6625/6 Series 6U CompactPCI® PlusIO blade with Intel® Core™ i7/i3 Processor
-
 ADLINK 3U CompactPCI CPU Modules
-
 ADLINK CM-435 Extreme Rugged™ PC/104 Single Board Computer
-
 ADLINK PCI-8254/8258 DSP-based 4/8-axis Advanced Motion Controllers
-
 ADLINK NuPRO-E43 PICMG® 1.3 Full-Size LGA1151 with 6th/7th Generation Intel® Core™ i7/i5/i3
-
 ADLINK DLAP-211-JNX/DLAP-211-JT2/ DLAP-211-Nano
-
 Hirschmann RS30-1602O6O6SDAE compact OpenRail managed Ethernet switches
-
Hirschmann RS30-0802O6O6SDAE Ethernet switch
-
 Hirschmann RS20-1600T1T1SDAE Management-type Ethernet switch
-
 Hirschmann OCTOPUS 24M Limited Availability/Passive
-
 Hirschmann MSP30-24040SCZ9MRHHE3A
-
 Hirschmann MAR1040-4C4C4C4C9999SMMHRHHXX.X. Gigabit Ethernet Switch configurator
-
 Hirschmann Industrial Ethernet Rail Switch SPIDER II, SPIDER II Giga, SPIDER II PoE
-
 Hirschmann Industrial Ethernet Firewall EAGLE One
-
 Hirschmann Industrial Security Router EAGLE20/30
-
 Hirschmann Description and operating instructions RS2-xTX/xFX EEC
-
 Basler Electric DECS-200 Digital Excitation Control System
-
 Basler Electric GENERATOR PROTECTION SYSTEM BE1-GPS100
-
 Jaquet FT3000 Speed measurement system
-
 Hirschmann Industrial Ethernet Ruggedized Switch MACH1000 Family
-
 Basler Electric BESTCOMSPlus®
-
 ETEL AccurET MODULAR 300 EA-P2M-300-xxxxxA controller
-
 Basler Electric ES Series Protection Relays
-
 ABB Multifunction Protection and Switchbay Control Unit REF542plus
-
 EMERSON AMS 2140 Machinery Health Analyzer
-
 Hirschmann Industrial Ethernet Rail Switch RS20 Basic Family
-
 GE Grid Solutions P40U Px40 USB Adaptor
-
 ABB ontinuous Gas Analyzers AO2000 Series AO2040CU Ex Central Unit in Category 2G
-
 ABB Advance Optima AO2000 Series Continuous gas analyzers Models AO2020. AO2040
-
 Advance Optima Module Uras 14
-
 SAACKE control optimization
-
 SAACKE se@vis efficiency monitor
-
 SAACKE se@vis pro
-
 SAACKE se@vis eco
-
 SAACKE se@vis compact
-
 HIRSCHMANN Industrial ETHERNET Switch MICE MS20/MS30
-
 HIRSCHMANN MICE Media modules
-
 Kongsberg GL-10 Level Switch
-
 B&R ACOPOSinverter P74 frequency converter
-
 Beckhoff CX2020 | Basic CPU module (service phase)
-
 Beckhoff CX1010 | Basic CPU module (service phase)
-
 Beckhoff CX5120 | Embedded PC with Intel Atom® E3815
-
 Beckhoff CP69xx-xxxx-0010 | Economy built-in Control Panel with DVI/USB Extended interface
-
 Beckhoff CP29xx-0000 | Multi-touch built-in Control Panel with DVI/USB Extended interface
-
 SAACKE Monoblock Rotary Cup Burner SKVJ-M
-
 ABB Plantguard Fault Tolerant Technology Architecture and Software
-
 OMRON H8PR-8/H8PR-8P H8PR-16/H8PR-16P H8PR-24/H8PR-24P Rotary Positioner
-
 ABB PFSA107-Z42 DTU Stressometer Digital Transmission Unit
-
 Nidec Mentor MP
-
 IBA ibaNet-E
-
 IBA FO Connection to Reflective Memory
-
 IBA FO Connection to Siemens Systems
-
 IBA Interface Cards For Fiber Optic Connections
-
 IBA Field and Drive Buses
-
 IBA ibaPADU-S Modular System
-
 IBA ibaMAQS
-
 STUCKE SYMAP®ARC
-
 STUCKE SYMAP®R
-
 STUCKE SYMAP®Compact
-
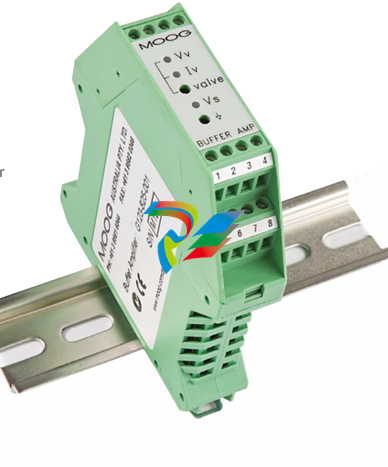 MOOG G123-825-001 BUFFER AMPLIFIER
-
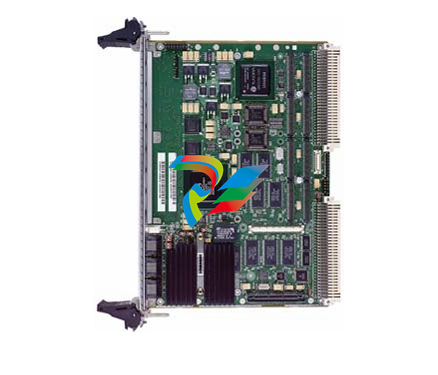 Motorola MVME5100 Series VME Processor Modules
-
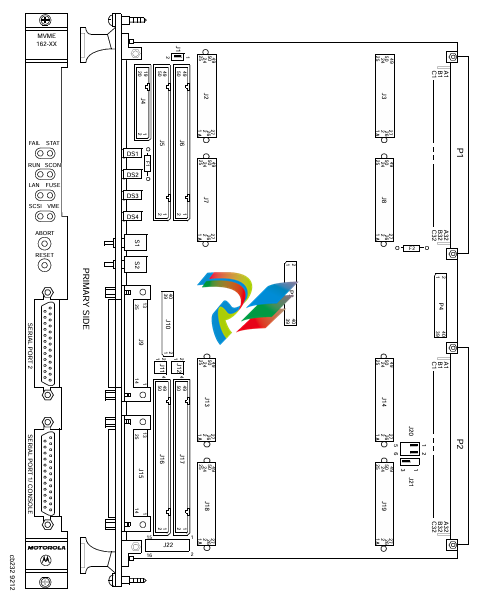 Motorola MVME162 Embedded Controller
-
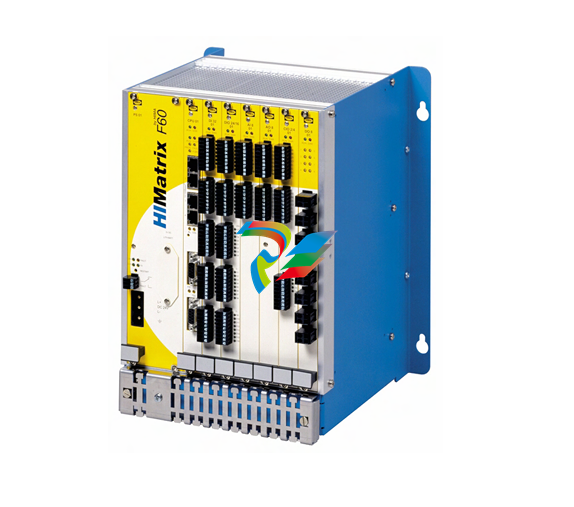 HIMatrix Safety-Related Controller System Manual for the Modular Systems
-
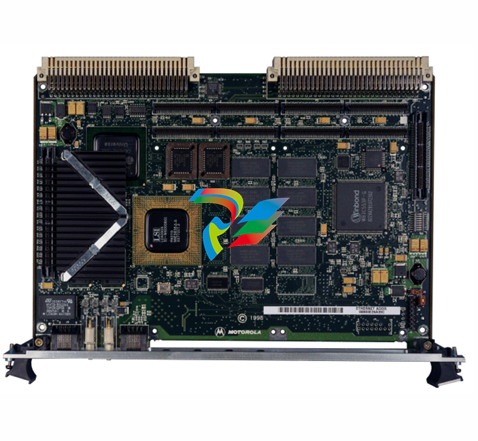 Motorola MVME2400 Series VME Processor Module
-
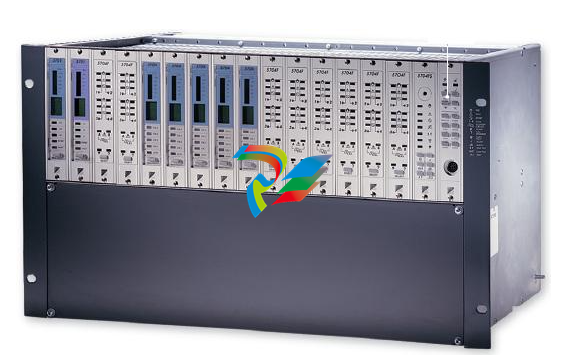 Sieger System 57
-
 KONGSBERG MRU product line continuation
-
 Woodward easYgen-3100/3200 Genset Control for Multiple Unit Operation
-
 Woodward MFR 300 Multifunction Relay / Measuring
-
 ABB AX410, AX411, AX413, AX416, AX418, AX450, AX455 and AX456 Single and dual input analyzers for low level conductivity
-
 ABB AX410, AX411, AX416, AX450 and AX455 Single and dual input analyzers
-
 Woodward easYgen-1400 Technical Manual Genset Control
-
 Woodward easYgen-400 Operation Manual Genset Control
-
 Woodward High Output Digital Valve Positioner (DVP)DVP5000/DVP10000/DVP12000
-
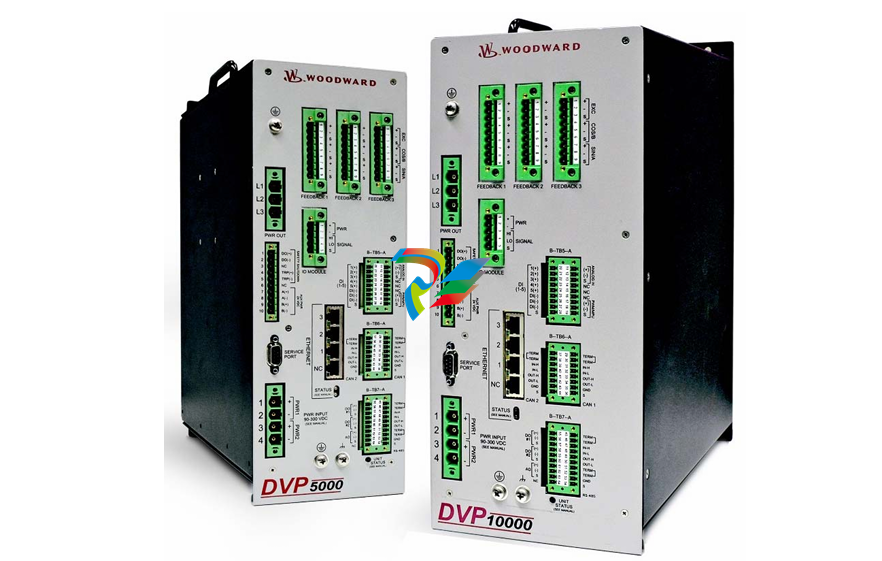 Woodward High Output Digital Valve Positioner DVP5000 and DVP10000
-
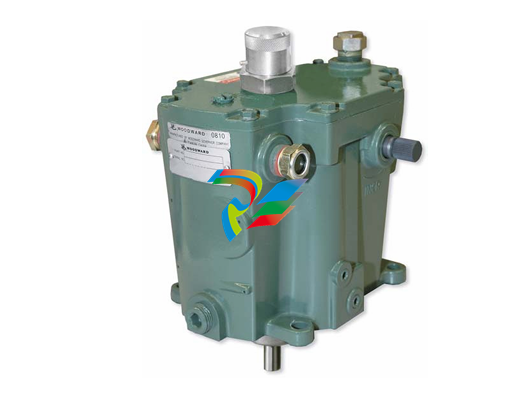 Woodward TG611-13/-17 Overspeed Test Device Conversion Kit
-
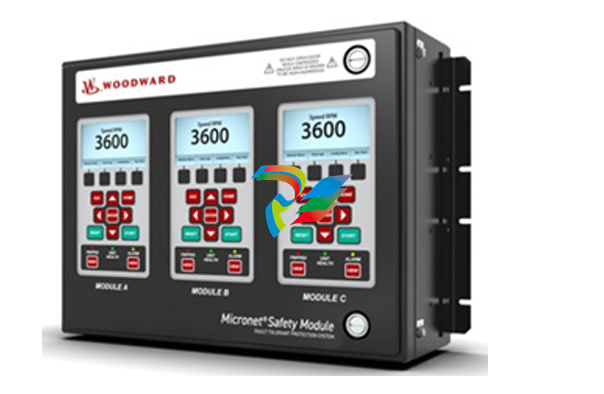 Woodward MicroNet Safety Module (MSM)
-
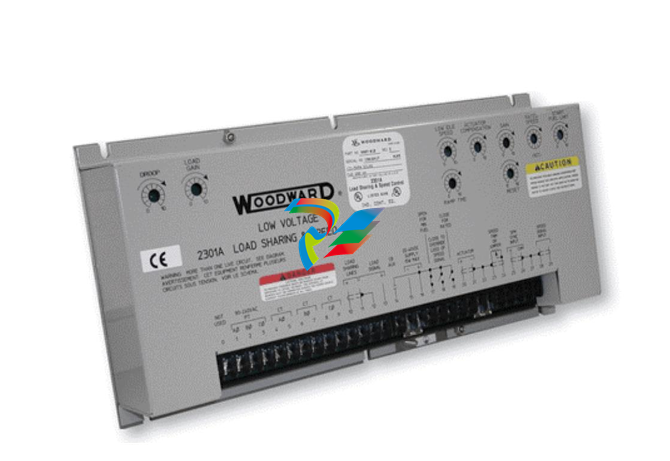 Woodward 2301A Electronic Load Sharing and Speed Control 9905/9907 Series
-
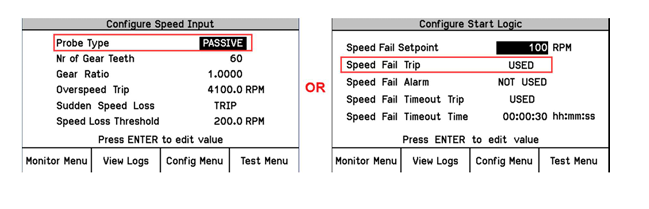 Woodward-Service Bulletin 01671
-
 UniOP eTOP40B 12.1” TFT color display
-
 UniOP eTOP40 TFT Color display
-
 UniOP eTOP33B 10.4” TFT color display
-
 UniOP eTOP33C eTOP33-0050 Resistive touchscreen
-
UniOP eTOP30. eTOP32 eTOP32-0050 Human-machine interface equipment
-
 UniOP eTOP20B and eTOP21B eTOP20B-0050
-
 UniOP eTOP12 eTOP12-0050 Advanced human-machine interface equipment
-
 UniOP eTOP11 eTOP11-0050 HMI
-
 UniOP eTOP06C HMI
-
 UniOP eTOP06 HMI
-
 UniOP eTOP05EB eTOP05EB-DF45 HMI
-
 UniOP eTOP05. eTOP05P Human-machine interface equipment
-
 UniOP eTOP03 eTOP03-0046
-
 UniOP eTOP507 507U2P1 eTOP Series 500 Human-Machine Interface
-
 UniOP eTOP307
-
 UniOP ETT-VGA Human-machine interface touch unit
-
 UniOP ePAD32B, ePAD33B and ePAD33BT ePAD33B-0350
-
 UniOP ePAD05 and ePAD06
-
 UniOP CP02R-04 Human-machine interface
-
 UniOP ERT-16 - Industrial PLC Workstation
-
 UniOP ePAD03 and ePAD04
-
 UNIOP EPALM10-DA71 state-of-the-art handheld HMI
-
 Watlow SERIES CLS200 SPECIFICATION SHEET
-
 Detailed Explanation of B&R Power Panel 300/400: The Core of Industrial Automation Control
-
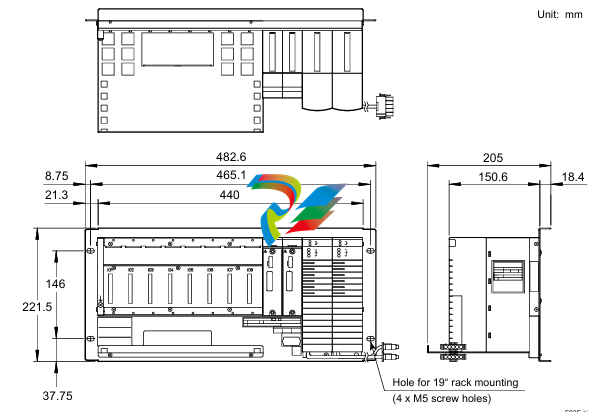 YOKOGAWA Models ANB10S, ANB10D, ANR10S, ANR10D Node Units (for FIO)
-
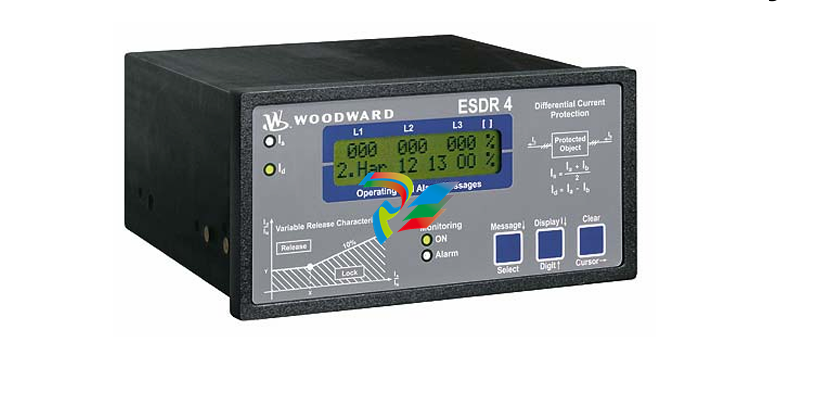 Woodward ESDR 4 Current Differential Protection Relay
-
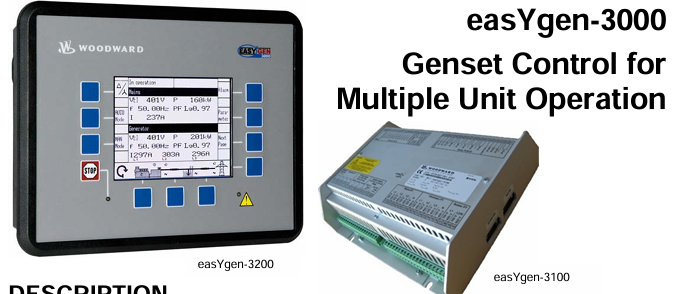 Woodward easYgen-3000 Genset Control for