Central unit PM 640 and PM 644: (supports SC 610)
Performance, in this thesis, refers to the capability of a communication component in means of speed and throughput. • Availability is the term for the probability that a system will perform its specified functions when used under stated conditions. A common mathematical definition of operational availability is Ao = MT BF/(MT BF + MDT), whereas MTBF is the “mean time between failure” and MDT the “mean down time” [2]. However, in this thesis, availability is used in a more general manner, since the basis for mathematical operations is not available.
Abstract In order to modernize their infrastructure and keep up with the state of the art, ABB Power Systems decided to replace the older controller AC450 with a new generation of controllers called AC800M. Just like its predecessor, its main task is to work as a sequencer in an otherwise mostly unchanging topology. Although the new controller AC800M provides modern communication features and a sophisticated application development system, it lacks of a communication interface compatible with the residing controllers AC160. A hardware approach addressing this problem is in development, but not available at this point of time. Thus the decision was made to realize the connection using OPC, a widely spread and open software communication interface standard with a high potential of reusability. In addition, it was aimed at gaining additional knowledge about the OPC interface, which is commonly used in industry. In this thesis, we evaluate adequate hardware and software to realize this connection and we have programmed the controllers with applications to evaluate its performance and integrity. In addition, we are making considerations about redundancy that is vital in automation business in order to increase reliability and availability. We have shown that it is possible to interconnect controllers using OPC with satisfactory average performance results. Due to high maximum round trip times and high complexity when realizing redundancy, it is recommended to use such a system for testing purposes or non-critical operational applications, but not for critical systems. In this thesis we also identify and judge several alternative ways of connection.
Acknowledgements First of all, I would like to thank Prof. Dr. Bernhard Plattner of the Computer Engineering and Networks Laboratory TIK at the Swiss Federal Institute of Technology ETH Zurich for supporting and supervising this Master’s Thesis. Special thanks go to my advisors Rainer Baumann and Bernhard Tellenbach of TIK for their straightforward and helpful support during my work. Secondly I would like to thank Dr. Esther Gelle and Pascal Aebli of ABB for enabling this Master’s Thesis in the first place as well as providing aid throughout this thesis. Special thanks also to Stephan Egli for supporting me with the first steps, Swen Woldau for numerous hints concerning AC160 and AF100 as well as Juerg Beck for AC800M tips and tricks. Finally I would like to thank everyone else at PSPD for the provided aid and making my work so convenient not only in a technical but also in a human manner. Baden, June 2007 Martin Pfister
Chapter 1 Introduction This chapter will provide a rough overview of the problem treated by this Master’s Thesis. All technical devices and expressions will be explained more precisely in the next chapter. Please note that since this is a public thesis, it does not contain sensitive company-internal data. 1.1 ABB Power Systems ABB Power Systems is one of the world’s leading providers of infrastructure for controlling combined cycle power stations and waste-to-energy plants. Such a plant control infrastructure includes several hardware parts consisting of controllers, input/output-boards and communication devices as well as many software components to engineer, run, observe and analyze the power plant. A power plant control system has to satisfy a broad variety of different needs, from the efficient and reliable control of the turbines and associated supporting functions (such as lube oil) to easy configuration and operation as well as to sophisticated analysis functions addressing technical and economical aspects. 1.2 Problem Statement Due to high investment costs, the technical management of power plants is a slowgoing business with long life-cycles. Thus, a considerable amount of hardware devices currently in use are tens of years old. For future applications within ABB Power Systems it will be necessary to connect a controller of the newest series used within ABB, Control IT AC800M, with an older controller of the type Advant Controller 160 (AC160). The problem is that these two controllers do not share a fast communication interface of similar type and therefore cannot communicate directly. The standard communication intended for AC160 is Advant Fieldbus 100 (AF100). However, AC800M can support a whole range of buses except for AF100. As a consequence, the communication must be implemented using some relaying technique.
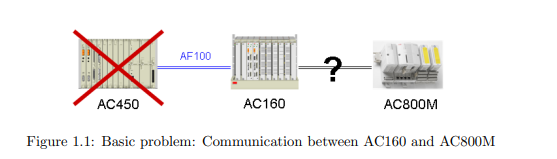
1.2.1 The Use of OPC It was decided in advance to realize the relaying connection using OPC. This solution was chosen because OPC is an open standard and very common in process and automation industry. Furthermore, this solution offers a high potential to be used for similar problems, since a lot of devices support this specification. However, OPC is normally not used for fast controller-to-controller communication but for slower visualization and logging purposes and there is no performance data available for this kind of connection. The use of OPC is therefore both challenging as well as interesting to gain more insights and know-how. It is also to mention that a hardware solution addressing our problem is not available yet. It is therefore necessary to have an alternative way using already available parts, also for testing purposes. 1.3 Goals The goals of this Master’s Thesis are stated as follows: • Setup and evaluation of a test environment • Setup of test systems • Theoretical and practical evaluation of the test systems concerning performance, availability and reliability. • Identification of improvements and different approaches • Comparison with alternatives As a starting point for the performance requirements, the current implementation was taken. The corresponding quantity and type of variables are displayed in Table 1.1 with 32-bit floating point values (floats) as analog in- and outputs and 1-bit boolean values as so-called status and command bits. In the current configuration with AC450 and AC160, all variables are written to the AF100 fieldbus with a cycle time of 256 milliseconds. Therefore we determined the minimum requirement for round-trip times from one controller to the other to exactly this time. In agreement with the advisors, instead of elaborating the optional extension stated in the task description (Appendix C), we spent more time on trying out a
-
 CTI 2500C-RBC-RS485 RS485 Remote Base Controller
-
 CTI 2500C-RBC-PRF Profibus Remote Base Controller
-
 CTI 2500C-PS-24V-35 35-Watt DC Power Supply
-
 CTI 2500C-PS-120V-35 35-Watt AC Power Supply
-
 CTI 2500C-R8 Eight-Slot Base
-
 CTI 2500C-R4 Four-Slot Base
-
 CTI 2500C-R16 Sixteen-Slot Base
-
 CTI 2500C-2572-B Fast Ethernet TCP/IP Adapter
-
 CTI 2500C-J750 Compact Janus PAC with 3MB Project Memory
-
 CTI 2500C-C300 CPU with 512K User Memory
-
 CTI 2500C-C200 CPU with 256K User Memory
-
 CTI 2500C-C100 CPU with 128K User Memory
-
 CTI 2500C-8-AO 8 Analog Outputs
-
 CTI 2500C-8-AI 8 Analog Inputs
-
 CTI 2559-FCAL Precision Calibration Connector
-
 CTI 2559-FPC 40-Position Screw-Terminal Connector
-
 CTI 2500-RFC PLC to RF Modem Cable
-
 CTI 2500-40F 40-Position Standard Screw-Terminal Connector
-
 CTI 2505 Vibration Sensor Interface Module
-
 CTI 2554-A 4-Channel Isolated High Speed Counter Module
-
 CTI 2553-A 2-Channel Mag Meter Input Module
-
 CTI 2502 2-Channel High Speed Counter Input Module
-
 CTI 2559-TC 8-Channel Thermocouple Input Module
-
 CTI 2556-A 16-Channel Isolated Thermocouple Input Module
-
 CTI 2556 16-Channel Isolated Thermocouple Input Module
-
 CTI 2551-A 8-Channel Isolated Thermocouple Input Module
-
 CTI 2559-RTD 8-Channel RTD Input Module
-
 CTI 2557-A 16-Channel RTD Input Module
-
 CTI 2557 16-Channel RTD Input Module
-
 CTI 2552-A 8-Channel Isolated RTD Input Module
-
 CTI 2534 8-Point Form-C Relay Output Module
-
 CTI 2532 16-Point Form-A Relay Output Module
-
 CTI 2531 32-Point Form-A Relay Output Module
-
 CTI 2530 8-Point Form-C Relay Output Module
-
 CTI 2562 8-Channel Analog Output Module
-
 CTI 2560-A 8-Channel Isolated Analog Output Module
-
 CTI 2501 8in/4out Analog Module
-
 CTI 2558 8-Channel Analog Input Module
-
 CTI 2555-A 16-Channel Analog Input Module
-
 CTI 2550-A 8-Channel Isolated Analog Input Module
-
 CTI 2599 8/16/32-Point AC Output Module
-
 CTI 2598-8 8-Point AC Output Module
-
 CTI 2598 8/16-Point AC Output Module
-
 CTI 2597 8/16/32-Point DC Output Module
-
 CTI 2596-8 8-Point DC Output Module
-
 CTI 2596 8/16-Point DC Output Module
-
 CTI 2595 16-Point TTL/Word Output Module
-
 CTI 2591-EF 16-Point Isolated 11-146 VDC Output with Front Panel Accessible Fuses
-
 CTI 2591-A 16-Point Isolated 11-146 VDC Output Module
-
 CTI 2590-EF 16-Point Isolated 20-132 VAC Output with Front Panel Accessible Fuses
-
 CTI 2590-A 16-Point Isolated Discrete 20-132 VAC Output Module
-
 CTI 2589-B 8/16/32-Point Universal Discrete Input Module
-
 CTI 2589-A 8/16/32-Point Universal Discrete Input Module
-
 CTI 2588-8 8-Point Universal Discrete Input Module
-
 CTI 2585 16-Point TTL/Word Input Module
-
 CTI 2582 16-Point Isolated 125 VDC Input Module
-
 CTI 2581 16-Point Isolated 12-56 VDC Input Module
-
 CTI 2580 16-Point Isolated 95-132 VAC Input Module
-
 CTI 2500-TAP RS485 Network Tap
-
 CTI 2500-RIO-B RS485 Remote Base Controller
-
 CTI 2500-RIO-A RS485 Remote Base Controller
-
 CTI 2500-RBC Profibus Remote Base Controller
-
 CTI 2515-A 100-Watt AC/DC Power Supply with Redundancy Support
-
 CTI 2515 100-Watt AC Power Supply (MATURE - replaced by 2515-A)
-
 CTI 2513-A 75-Watt DC Power Supply with Redundancy Support
-
 CTI 2513 75-Watt 24VDC Power Supply
-
 CTI 2512-A 75-Watt AC/DC Power Supply with Redundancy Support
-
 CTI 2512 75-Watt AC/DC Power Supply
-
 CTI 2510 125 VDC Power Supply
-
 CTI 2500-SSB Single Slot Blank Front Panel
-
 CTI 2500-R11-A Eleven-Slot Redundant Base
-
 CTI 2500P-R16 Sixteen-Slot Base with High-Speed Channel
-
 CTI 2500P-R8 Eight-Slot Base with High-Speed Channel
-
 CTI 2500P-R4 Four-Slot Base with High-Speed Channel
-
 CTI 2541 Redundant Processor Manager Module
-
 CTI 2577 Profibus DP Slave Adapter
-
 CTI 2573-MOD Serial Interface Adapter with MODBUS
-
 CTI 2572-AF Fast Ethernet TCP/IP Adapter with Optical Fiber Connection
-
 CTI 2572-A Fast Ethernet TCP/IP Adapter
-
 CTI 2572 Ethernet TCP/IP Adapter
-
 CTI 2572-B Fast Ethernet TCP/IP Adapter
-
 CTI 2576 DeviceNet™ Scanner Module (MATURE)
-
 CTI 2500P-ECC1 Ethernet Communications Coprocessor
-
 CTI 2500P-JACP Janus Application Coprocessor
-
 CTI 2500P-ACP1 Application Coprocessor (MATURE - replaced by 2500P-JACP)
-
 CTI 2500P-J450 Janus PAC with 2MB Project Memory
-
 CTI 2500-C400 CPU with 3072K User Memory
-
 CTI 2500-C300 CPU with 512K User Memory
-
 CTI 2500-C200 CPU with 256K User Memory
-
 CTI 2500-C100 CPU with 128K User Memory
-
 CTI 2500P-J750 Janus PAC with 3MB Project Memory
-
 Shinkawa WHF3006M Displacement Converter
-
Shinkawa JBP-220 (P-24-94A / P-24-94B) Circuit Board Module
-
 SHINKAWA WKN-142K5 2-WIRE VIBRATION TRANSDUCER
-
Shinkawa FRP-321 (P-26-54A / P-26-54B) Circuit Board Module
-
 Shinkawa IOP-160 (P-25-72A / P-25-72B) Circuit Board Module
-
 Shinkawa PK-147B-1 / PK-147A-1 Circuit Board Module
-
 Shinkawa CPP-91A Circuit Board Module
-
 Shinkawa FRP-177 PCB Module
-
 Shinkawa CPP-127 (P-26-74A / P-26-74B) Circuit Board Module
-
Shinkawa FRP-227 (P-24-86A / P-24-86B) Circuit Board Module
-
 Shinkawa MDP-104 (P-25-83A / P-25-83B) Circuit Board Controller
-
 Shinkawa VK-143P2 High-precision eddy current sensor driver/signal conditioner
-
 Shinkawa FRP-226 (P-24-86A / P-24-86B) Circuit Board Module
-
Shinkawa CPP-107A P-22-99A P-22-99B Circuit Board Module
-
 SHINKAWA VW-202AL-8 Axial Displacement Sensor
-
Shinkawa VL-202A08L-1A42 Vibration Sensor Transducer Probe
-
Shinkawa VL-202A08L-1A42 Vibration Sensor Transducer Probe
-
 Shinkawa FRP-209A & FRP-206 Wire Bonder Circuit Board Module
-
 Shinkawa MGP-72 MGP72 P-26-50A P-26-50B Circuit Board Module
-
 Shinkawa FRP-249 P-25-1A P-25-1B Circuit Board Module
-
Shinkawa FRP-320 P-26-54A P-26-54B Circuit Board Module
-
Shinkawa FRP-282 P-24-35A P-24-35B Circuit Board Module
-
 Shinkawa FRP-338 P-26-54A P-26-54B Circuit Board Module
-
 GE IS200AEPBH1B IS200AEPBH1B‑REV‑AA Pitch-Charger Control PCB Board
-
 GE IS200EDEXG1ADA EX2100 SCR Trigger Control Board
-
 GE 151X1207CK01SA01 IS200EDEXG1A EX2100 SCR
-
 GE 151X1233DD02SA02 IS200AEPBH1B - Variant for pitch control charger assembly
-
 GE 151X1233DB01SA01 IS200AEPBH1B - 10kW Wind Power Converter
-
 GE 151X1233DB01SA01R | IS200AEPBH1B 10KW Converter
-
GE 151X1233DD01SA02 Pitch Battery Charger (109W6931P001)
-
GE 151X1233DD01SA02 Pitch Battery Charger Assy IS200AEPBH1B
-
 GE 151X1233DB02SA02 Rev A IS200AEPBH1B Wind Turbine Converter
-
 GE 151X1207CK02SA02 SCR 4400 V 1850 A IS200EDEXG1ADA General Electric EX2100
-
 Triconex 3723X 32-Channel TMR Analog Input Module with HART
-
 SHINKAWA VM-21G SIGNAL CONDITIONER SOCKET
-
SHINKAWA VM-21R REVOLUTION SIGNAL CONDITIONER
-
SHINKAWA VM-21T DISPLACEMENT INPUT THRUST SIGNAL CONDITIONER