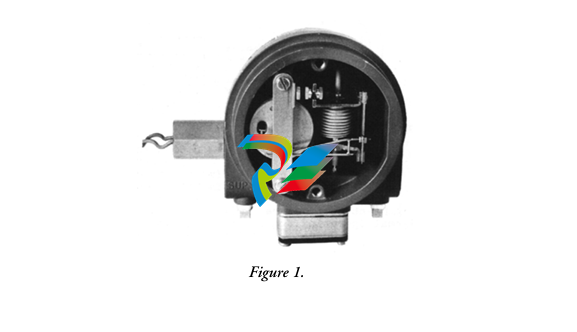
Foxboro E69F Current-to-Pneumatic Signal Converter
E69F Current-to-Pneumatic
Signal Converter
Introduction
General Description
TheE69F Current-to-Pneumatic Signal Converter (Figure 1) is a field-mounted instrument that
transforms a dc milliampere input signal to a proportional pneumatic output signal.
This output signal can be used either to operate such pneumatic devices as dampers, and valve
actuators, and so forth, or as the input to various pneumatic instruments.
Principle of Operation
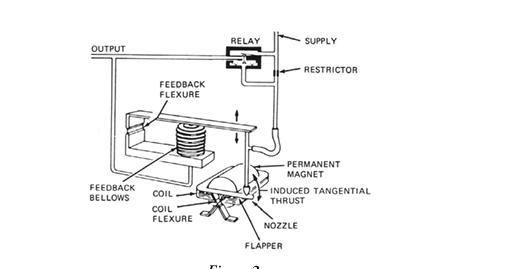
A dc milliampere input signal is converted to a proportional pneumatic output signal in the fol
lowing manner (see Figure 2). A coil positioned in the field of a permanent magnet reacts to the
current by producing a tangential thrust proportional to the input signal flowing through it. The
thrust, acting through coil flexures, varies the gap between a flapper and a nozzle. This causes a
change in the output pressure of the relay, which is also the converter output pressure. This pres
sure is fed to a feedback bellows which exerts a force on a feedback flexure to move the nozzle and
establish a throttling relationship between the flapper and the nozzle
Standard Specifications
Input and Output Ranges
Input Ranges (mA)
kPa
Output Ranges(3)
4 to 20(1)
or
20 to 100
40 to 200
7 to 125
7 to 220
psi
3 to 15
3 to 27
6 to 30
1 to 18
1 to 32
10 to 50(2)
(1) 4 to 12 or 12 to 20 mA. Split ranges available with addition of a flat spring.
(2) 10 to 30 or 30 to 50 mA. Split ranges available with addition of a flat spring.
(3) Direct or reverse, as specified.
NOTE
Ranges are listed in kPa and psi. For alternative ranges in kg/cm2 or bar, divide
applicable kPa values by 100.
Supply Pressure
Nominal
140 kPa or 20 psi
Limits
130 and 160 kPa or 19 and 23 psi
240 kPa or 35 psi
225 and 260 kPa or 33 and 38 psi
Supply pressure must not be less than 20 kPa or 3 psi above the maximum signal.
Input Resistance
4 to 20 mA Input: 170 Ω
10 to 50 mA Input: 27 Ω
Air Consumption
20 to 100 kPa or 3 to 15 psi output:
40G Relay: 0.5 m3/h (0.30 cfm) at standard conditions.
All other outputs: 40D Relay:
1.3 m3/h (0.75 cfm) at standard conditions with 140 kPa or 20 psi supply.
1.7 m3/h (1.0 cfm) at standard conditions with 240 kPa or 35 psi supply.
Ambient Temperature Limits
Normal Operating Conditions:-30 and +60°C (-20 and +140°F)
Operative Limits: -40 and +80°C (-40 and +180°F)
Calibrated Accuracy
±0.5% of span; but ±2% of span with output signals of 7 to 125 and 7 to 220 kPa or 1 to 18
and 1 to 32 psi
Mass
(Approximate) 2.3 kg (5 lb)
Product Safety
For electrical classification of converter, refer to data plate. For conditions of certification, refer to
Calibration
For simplicity, the procedure below assumes a converter with a 4 to 20 mA input and a 20 to
100 kPa or 3 to 15 psi output. For other ranges, substitute the applicable values. The specific
input and output are listed on the converter data plate.
Equipment Setup
Calibration setup is shown in Figure 7.
Any adjustment to the span will interact with the zero adjustment and will change
the initial zero setting. Therefore, any adjustment made to the span must be
followed by readjustment of zero.
1. Set up equipment as shown in Figure 7.
2. Apply 12 mA (50%) input to converter and adjust output (zero screw) to 60 kPa or
9 psi (50%). See Figure 8.
3. Apply 20 mA (100%) input to converter and note amount of error above or below
100 kPa or 15 psi (100%) output. If error is greater than ±2% (1.6 kPa or 0.025 psi),
perform Step 4. If error is less than ±2%, proceed to Step 5.
4. Loosen 5/16-inch bellows locknut. Note reference line on bellows. Rotate bellows1 so
that reference line moves toward motor to decrease span or away from motor to
increase span until the error is within ±2%. Tighten bellows locknut.
Repeat Steps 2 and 3.
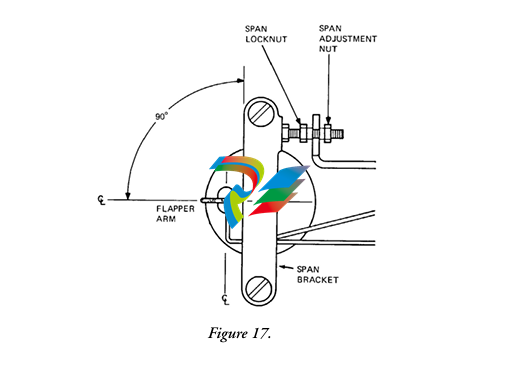
5. See Figure 9. Loosen the 5/16-inch span locknut and turn the 5/16-inch span
adjustment nut a proportional amount (noted in Step 3) based on the following: 1/6
of a turn (point to point on the hexagonal nut) corrects the error by 0.5%.
7. Apply 12 mA (50%) input to converter and adjust output (zero screw) to 60 kPa or
9 psi (50%).
8
8. Apply 20 mA (100%) input and check output for 100 kPa or 15 psi (100%). If
output is not correct, repeat Steps 5 through 7.
9. Apply 4 mA (0%) and check output for 20 kPa or 3 psi (0%). If necessary, readjust
zero screw for correct output.
10. Apply 100% input and check output. If output is not correct, repeat Steps 5 and 8
until both 0% and 100% outputs are correct.
Maintenance
Relay Maintenance
To Remove Relay
Remove the two large screws and pry off relay. See Figure 11. A gasket is supplied with each
replacement relay.
For maintenance details, see Instruction MI 011-493 (Model 40G) or MI 011-491 (Model 40D).
To Clean Restrictor
Remove relay. See “To Remove Relay” procedure.
Clean by inserting a 0.1 mm (0.005 in) diameter wire (or Foxboro cleaning wire, Part 0042527)
through
t up equipment as shown inFigure 77. 2. Apply 12 mA (50%) input to converter and adjust output (zero screw) to 60 kPa or 9 psi (50%). SeeFigure 88.
3. Apply 20 mA (100%) input to converter and note amount of error above or below 100 kPa or 15 psi (100%) output. If error is greater than ±2% (1.6 kPa or 0.025 psi), perform Step 4. If error is less than ±2%, proceed to Step 5.
Figure 8.
4. Loosen 5/16-inch bellows locknut. Note reference line on bellows. Rotate bellows1 so that reference line moves toward motor to decrease span or away from motor to increase span until the error is within ±2%. Tighten bellows locknut.
Repeat Steps 2 and 3. 5. SeeFigure 99. Loosen the 5/16-inch span locknut and turn the 5/16-inch span adjustment nut a proportional amount (noted in Step 3) based on the following: 1/6 of a turn (point to point on the hexagonal nut) corrects the error by 0.5%.
1. Bellows Assembly is on an eccentric.
7
MI 018-430 – June 2005
CAUTION
The span locknut must be loosened prior to span adjustment. Do not force nuts against each other to make small span changes. Forcing nuts together could result in
stripping of threads.
6. Disregard output changes that occur when span adjustment is made. Tighten span locknut.
CAUTION
Do not overtighten span locknut when locking in place as threads could become
stripped.
Figure 9.
Figure 10.
7. Apply 12 mA (50%) input to converter and adjust output (zero screw) to 60 kPa or 9 psi (50%).
8
MI 018-430– June 2005
8. Apply 20 mA (100%) input and check output for 100 kPa or 15 psi (100%). If output is not correct, repeat Steps 5 through 7.
9. Apply 4 mA (0%) and check output for 20 kPa or 3 psi (0%). If necessary, readjust zero screw for correct output.
10. Apply 100% input and check output. If output is not correct, repeat Steps 5 and 8 until both 0% and 100% outputs are correct.
Maintenance
Relay Maintenance
To Remove Relay
Remove the two large screws and pry off relay. SeeFigure 1111. A gasket is supplied with each replacement relay. For maintenance details, see Instruction MI 011-493 (Model 40G) or MI 011-491 (Model 40D).
CAUTION
If converter is equipped with explosionproof cover, three flame arresters are present.
Arresters must remain in place for explosionproof protection.
Figure 11.
To Clean Restrictor
Remove relay. See“To Remove Relay” procedure.
Clean by inserting a 0.1 mm (0.005 in) diameter wire (or Foxboro cleaning wire, Part 0042527) through orifice.
9
MI 018-430 – June 2005
Converter Modifications
NOTE
Foxboro does not consider the following modifications a field conversion. They are considered factory modifications due to the complexity of the procedures and the large amount of time required to perform them. If the modifications must be made in the field, use the following procedures and contact Foxboro for additional
assistance.
To Reverse Converter Action
The existing action of the converter is indicated by the marking on the exposed top of the motor cover: INC-INC (increasing input produces an in
creasing output), or INC-DEC (increasing
input produces a de
creasing output). When reinstalling the motor (Step 9 below), the exposed marking on the motor cover must indicate the desired action. 1. Disconnect instrument from installation (input wiring, air lines, and mounting bolts). 2. Remove two screws holding span bracket. SeeFigure 1212.
Figure 12.
3. Remove two screws holding feedback assembly (with bellows). Note routing of tubing for later replacement.
NOTE
Do not remove mounting plate from feedback assembly. Remove as a unit.
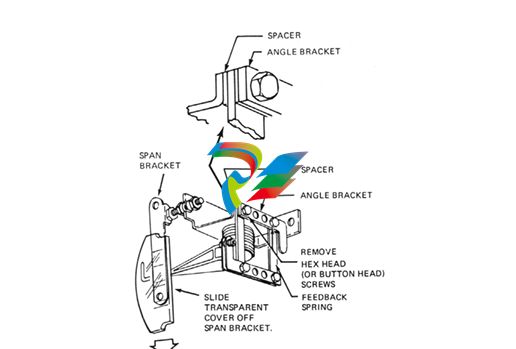
4. Lift aside feedback assembly (do not damage nozzle) to expose spring on bottom of case. Slide transparent cover off span bracket as shown inFigure 1313. Unhook spring from motor bracket.
(For convenience, feedback assembly can be removed entirely by disconnecting tubing. Note identification of tubing for later reconnection.)
10
MI 018-430– June 2005
5. On feedback assembly, remove two hex head (formerly buttonhead) screws. Interchange locations of angle bracket and spacer. SeeFigure 1313.
Reinstall hex head screws and tighten to a torque of 3.4 to 4.0 N•m (30 to 35 lb•in). Switching locations of angle bracket and spacer allows the Ni-Span angle bracket to correct for temperature induced errors in the INC-DEC mode.
Figure 13shows parts in INC-INC arrangement.
Figure 13.
6. Remove hex columns (use 5/16-inch wrench), and lift off motor pivot plate. SeeFigure 1212.
7. Lift out motor. Carefully lift flapper straight up from flapper arm on motor. Do not deform flapper. Holding on to flapper arm on other end of motor while removing will prevent internal motor flexure deformation.
8. Remove two screws holding bracket to bottom of motor. SeeFigure 1414. Invert motor and reinstall bracket (on side of motor that was formerly on top).
11
MI 018-430 – June 2005
Figure 14.
9. Wind excess wire clockwise around motor and carefully place motor into position in the case assuring that bottom arm is
-
 CTI 2559-TC 8-Channel Thermocouple Input Module
-
 CTI 2556-A 16-Channel Isolated Thermocouple Input Module
-
 CTI 2556 16-Channel Isolated Thermocouple Input Module
-
 CTI 2551-A 8-Channel Isolated Thermocouple Input Module
-
 CTI 2559-RTD 8-Channel RTD Input Module
-
 CTI 2557-A 16-Channel RTD Input Module
-
 CTI 2557 16-Channel RTD Input Module
-
 CTI 2552-A 8-Channel Isolated RTD Input Module
-
 CTI 2534 8-Point Form-C Relay Output Module
-
 CTI 2532 16-Point Form-A Relay Output Module
-
 CTI 2531 32-Point Form-A Relay Output Module
-
 CTI 2530 8-Point Form-C Relay Output Module
-
 CTI 2562 8-Channel Analog Output Module
-
 CTI 2560-A 8-Channel Isolated Analog Output Module
-
 CTI 2501 8in/4out Analog Module
-
 CTI 2558 8-Channel Analog Input Module
-
 CTI 2555-A 16-Channel Analog Input Module
-
 CTI 2550-A 8-Channel Isolated Analog Input Module
-
 CTI 2599 8/16/32-Point AC Output Module
-
 CTI 2598-8 8-Point AC Output Module
-
 CTI 2598 8/16-Point AC Output Module
-
 CTI 2597 8/16/32-Point DC Output Module
-
 CTI 2596-8 8-Point DC Output Module
-
 CTI 2596 8/16-Point DC Output Module
-
 CTI 2595 16-Point TTL/Word Output Module
-
 CTI 2591-EF 16-Point Isolated 11-146 VDC Output with Front Panel Accessible Fuses
-
 CTI 2591-A 16-Point Isolated 11-146 VDC Output Module
-
 CTI 2590-EF 16-Point Isolated 20-132 VAC Output with Front Panel Accessible Fuses
-
 CTI 2590-A 16-Point Isolated Discrete 20-132 VAC Output Module
-
 CTI 2589-B 8/16/32-Point Universal Discrete Input Module
-
 CTI 2589-A 8/16/32-Point Universal Discrete Input Module
-
 CTI 2588-8 8-Point Universal Discrete Input Module
-
 CTI 2585 16-Point TTL/Word Input Module
-
 CTI 2582 16-Point Isolated 125 VDC Input Module
-
 CTI 2581 16-Point Isolated 12-56 VDC Input Module
-
 CTI 2580 16-Point Isolated 95-132 VAC Input Module
-
 CTI 2500-TAP RS485 Network Tap
-
 CTI 2500-RIO-B RS485 Remote Base Controller
-
 CTI 2500-RIO-A RS485 Remote Base Controller
-
 CTI 2500-RBC Profibus Remote Base Controller
-
 CTI 2515-A 100-Watt AC/DC Power Supply with Redundancy Support
-
 CTI 2515 100-Watt AC Power Supply (MATURE - replaced by 2515-A)
-
 CTI 2513-A 75-Watt DC Power Supply with Redundancy Support
-
 CTI 2513 75-Watt 24VDC Power Supply
-
 CTI 2512-A 75-Watt AC/DC Power Supply with Redundancy Support
-
 CTI 2512 75-Watt AC/DC Power Supply
-
 CTI 2510 125 VDC Power Supply
-
 CTI 2500-SSB Single Slot Blank Front Panel
-
 CTI 2500-R11-A Eleven-Slot Redundant Base
-
 CTI 2500P-R16 Sixteen-Slot Base with High-Speed Channel
-
 CTI 2500P-R8 Eight-Slot Base with High-Speed Channel
-
 CTI 2500P-R4 Four-Slot Base with High-Speed Channel
-
 CTI 2541 Redundant Processor Manager Module
-
 CTI 2577 Profibus DP Slave Adapter
-
 CTI 2573-MOD Serial Interface Adapter with MODBUS
-
 CTI 2572-AF Fast Ethernet TCP/IP Adapter with Optical Fiber Connection
-
 CTI 2572-A Fast Ethernet TCP/IP Adapter
-
 CTI 2572 Ethernet TCP/IP Adapter
-
 CTI 2572-B Fast Ethernet TCP/IP Adapter
-
 CTI 2576 DeviceNet™ Scanner Module (MATURE)
-
 CTI 2500P-ECC1 Ethernet Communications Coprocessor
-
 CTI 2500P-JACP Janus Application Coprocessor
-
 CTI 2500P-ACP1 Application Coprocessor (MATURE - replaced by 2500P-JACP)
-
 CTI 2500P-J450 Janus PAC with 2MB Project Memory
-
 CTI 2500-C400 CPU with 3072K User Memory
-
 CTI 2500-C300 CPU with 512K User Memory
-
 CTI 2500-C200 CPU with 256K User Memory
-
 CTI 2500-C100 CPU with 128K User Memory
-
 CTI 2500P-J750 Janus PAC with 3MB Project Memory
-
 Shinkawa WHF3006M Displacement Converter
-
Shinkawa JBP-220 (P-24-94A / P-24-94B) Circuit Board Module
-
 SHINKAWA WKN-142K5 2-WIRE VIBRATION TRANSDUCER
-
Shinkawa FRP-321 (P-26-54A / P-26-54B) Circuit Board Module
-
 Shinkawa IOP-160 (P-25-72A / P-25-72B) Circuit Board Module
-
 Shinkawa PK-147B-1 / PK-147A-1 Circuit Board Module
-
 Shinkawa CPP-91A Circuit Board Module
-
 Shinkawa FRP-177 PCB Module
-
 Shinkawa CPP-127 (P-26-74A / P-26-74B) Circuit Board Module
-
Shinkawa FRP-227 (P-24-86A / P-24-86B) Circuit Board Module
-
 Shinkawa MDP-104 (P-25-83A / P-25-83B) Circuit Board Controller
-
 Shinkawa VK-143P2 High-precision eddy current sensor driver/signal conditioner
-
 Shinkawa FRP-226 (P-24-86A / P-24-86B) Circuit Board Module
-
Shinkawa CPP-107A P-22-99A P-22-99B Circuit Board Module
-
 SHINKAWA VW-202AL-8 Axial Displacement Sensor
-
Shinkawa VL-202A08L-1A42 Vibration Sensor Transducer Probe
-
Shinkawa VL-202A08L-1A42 Vibration Sensor Transducer Probe
-
 Shinkawa FRP-209A & FRP-206 Wire Bonder Circuit Board Module
-
 Shinkawa MGP-72 MGP72 P-26-50A P-26-50B Circuit Board Module
-
 Shinkawa FRP-249 P-25-1A P-25-1B Circuit Board Module
-
Shinkawa FRP-320 P-26-54A P-26-54B Circuit Board Module
-
Shinkawa FRP-282 P-24-35A P-24-35B Circuit Board Module
-
 Shinkawa FRP-338 P-26-54A P-26-54B Circuit Board Module
-
 GE IS200AEPBH1B IS200AEPBH1B‑REV‑AA Pitch-Charger Control PCB Board
-
 GE IS200EDEXG1ADA EX2100 SCR Trigger Control Board
-
 GE 151X1207CK01SA01 IS200EDEXG1A EX2100 SCR
-
 GE 151X1233DD02SA02 IS200AEPBH1B - Variant for pitch control charger assembly
-
 GE 151X1233DB01SA01 IS200AEPBH1B - 10kW Wind Power Converter
-
 GE 151X1233DB01SA01R | IS200AEPBH1B 10KW Converter
-
GE 151X1233DD01SA02 Pitch Battery Charger (109W6931P001)
-
GE 151X1233DD01SA02 Pitch Battery Charger Assy IS200AEPBH1B
-
 GE 151X1233DB02SA02 Rev A IS200AEPBH1B Wind Turbine Converter
-
 GE 151X1207CK02SA02 SCR 4400 V 1850 A IS200EDEXG1ADA General Electric EX2100
-
 Triconex 3723X 32-Channel TMR Analog Input Module with HART
-
 SHINKAWA VM-21G SIGNAL CONDITIONER SOCKET
-
SHINKAWA VM-21R REVOLUTION SIGNAL CONDITIONER
-
SHINKAWA VM-21T DISPLACEMENT INPUT THRUST SIGNAL CONDITIONER
-
SHINKAWA VM-21D 6-WIRE LVDT SIGNAL CONDITIONER
-
 SHINKAWA VM-21P 3-WIRE LVDT SIGNAL CONDITIONER
-
SHINKAWA VM-21A VIBRATION SIGNAL CONDITIONER
-
SHINKAWA VM-21K DISPLACEMENT INPUT VIBRATION SIGNAL CONDITIONER
-
 SHINKAWA VM-25S01 CONDITION MONITORING SYSTEM
-
SHINKAWA VM-25 CONDITION MONITORING SYSTEM
-
SHINKAWA VM-772B DEVICE CONFIG
-
SHINKAWA VM-771B MCL VIEW
-
 SHINKAWA VM-76B INSTRUMENT RACK
-
SHINKAWA VM-75B POWER SUPPLY MODULE
-
 SHINKAWA VM-742B NETWORK COMMUNICATION MODULE
-
 SHINKAWA VM-741B LOCAL COMMUNICATION & PHASE MARKER MODULE
-
SHINKAWA VM-722B 9-CHANNEL RELAY MODULE
-
SHINKAWA VM-707B AERODERIVATIVE GAS TURBINE MONITOR MODULE
-
 SHINKAWA VM-706B ROD DROP MONITOR MODULE
-
 SHINKAWA VM-705B 18-CHANNEL TEMPERATURE MONITOR MODULE
-
SHINKAWA VM-704B TEMPERATURE MONITOR MODULE
-
 SHINKAWA VM-702B ABSOLUTE VIBRATION MONITOR MODULE
-
SHINKAWA VM-701B VIBRATION / DISPLACEMENT MONITOR MODULE
-
 SHINKAWA MODEL VM-5X INTERFACE UNIT
-
 SHINKAWA MODEL VM-5W2 DUAL POWER SUPPLY INSTRUMENT RACK
-
 SHINKAWA MODEL VM-5H4 INSTRUMENT RACK (for VM-5Z5.6.7)